Vision and Endoscopy Module
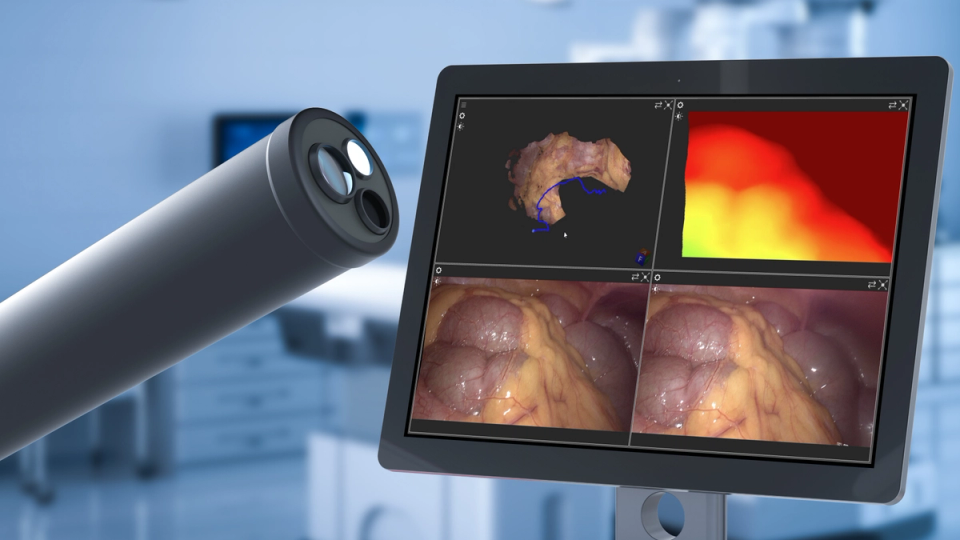
Medical and industrial vision, in one toolkit
We build vision modules for medical and industrial work: high-performance, product-grade features and visual prototyping tools, so the same building blocks drop into your workflow.
From prototype to interventional application
We deliver a medical-grade vision stack — from camera calibration to SLAM, mesh processing, and tissue tracking — that you can take from prototype to interventional application without a separate toolchain.
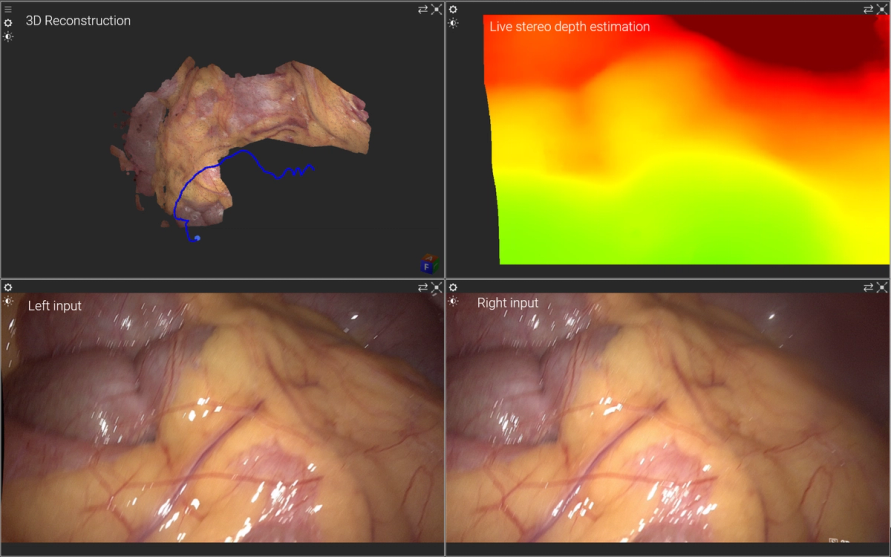
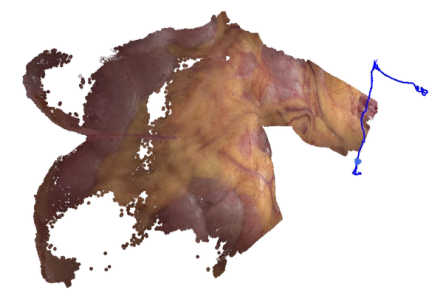
Endoscopic 3D and SLAM
We extract spatial data from endoscopic video for measurement, pre-op segmentation registration, and local mapping — including monocular video to 3D. Stereo, RGB-D, and monocular SLAM pipelines sit alongside tool segmentation.
- Endoscopic stereo SLAM and surfel-based reconstruction
- RGB-D, stereo, and monocular SLAM; Orbbec, Kinect, RealSense
- Tool segmentation and tissue segmentation
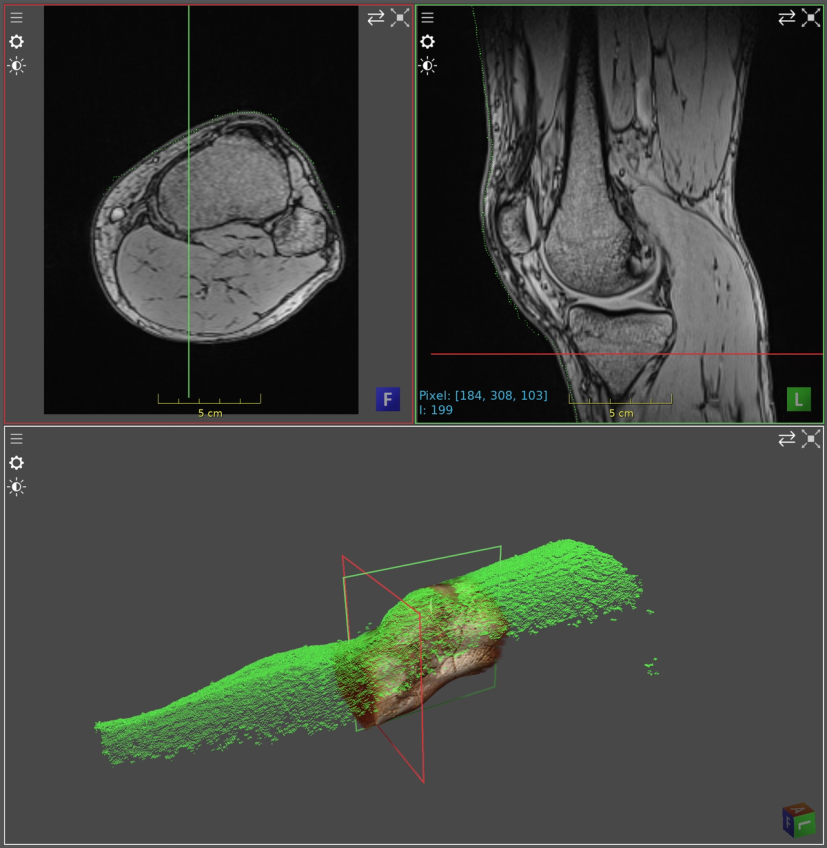
Surface registration and 6D pose
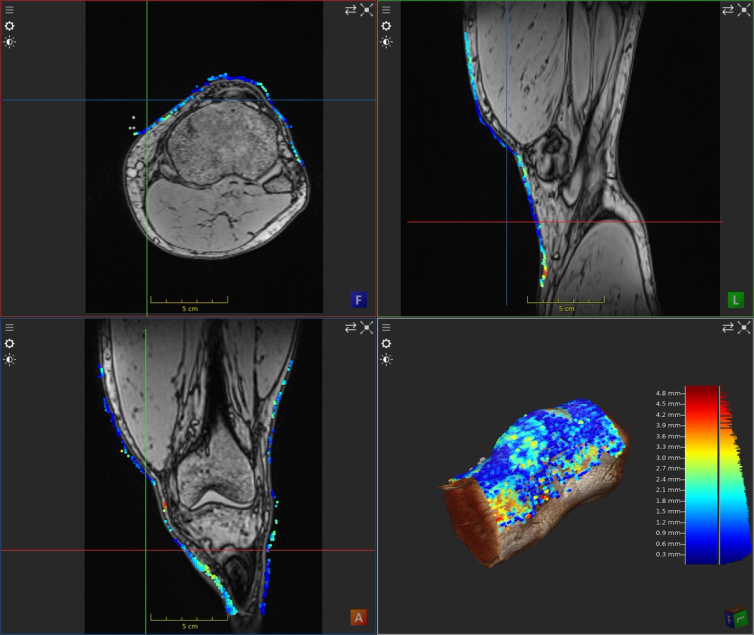
We register surfaces and volumes, and estimate object pose from images for endoscopic or industrial work — including shape matching, ICP / MAICP, and pose graph optimization.
- Surface registration: ICP, MAICP, pose graph optimization
- Shape matching and 6D pose estimation
- Volume-to-surface registration and fiducial marker tracking
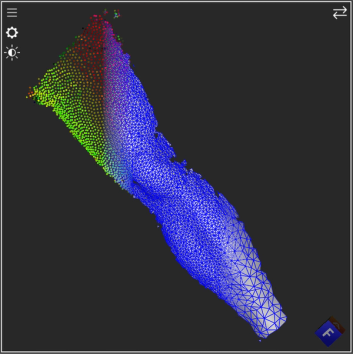
Computational geometry
We process meshes and point clouds with filtering, reconstruction, and collision tools. Camera calibration, stereo reconstruction, optical flow, and OpenXR rendering round out the stack.
- Surface reconstruction from point clouds; mesh crop, filter, smooth, reduce
- Camera calibration (single, stereo, RGB-D, hand-eye)
- Stereo rendering to HMDs and other OpenXR devices
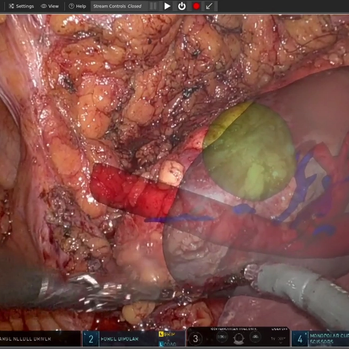
Endoscopic Tissue Tracking
Together with clinical partners at Orsi, we track a pre-op segmentation in endoscopic video as the camera moves and tissue is interacted with. Stereo depth, optical flow, and feature tracking work in one pipeline (including Holoscan).
- Stereo depth reconstruction, optical flow, and feature tracking
- Pre-op segmentation followed through camera motion and tissue interaction
- Developed with clinical partners at Orsi
Video tutorials
Endoscopic Stereo SLAM
Surface Registration
Get a technical walkthrough of the platform to see our key workflows in action and assess fit.
Product Demo
In a product demo, we show you how the ImFusion Suite, SDK, and ImFusion Labels support medical imaging and data annotation workflows. We focus on the capabilities relevant to your application and discuss directly how our technology could fit into your product or support your use case.
- See integration points mapped to your specific tech stack
- Identify bottlenecks before committing development resources
- Validate data format compatibility and transformation requirements
- Get immediate answers from engineers who built the system