Robotics Module
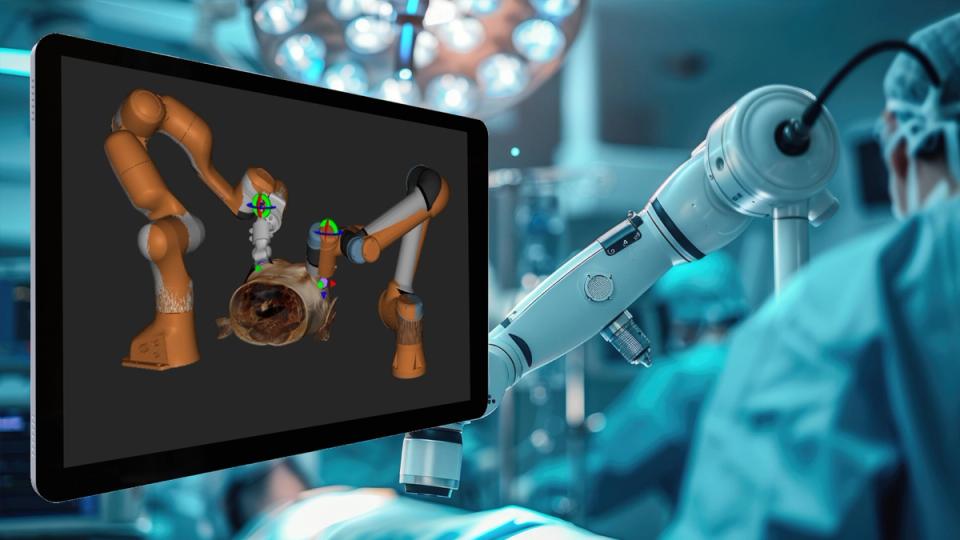
Building blocks for real-time robotics
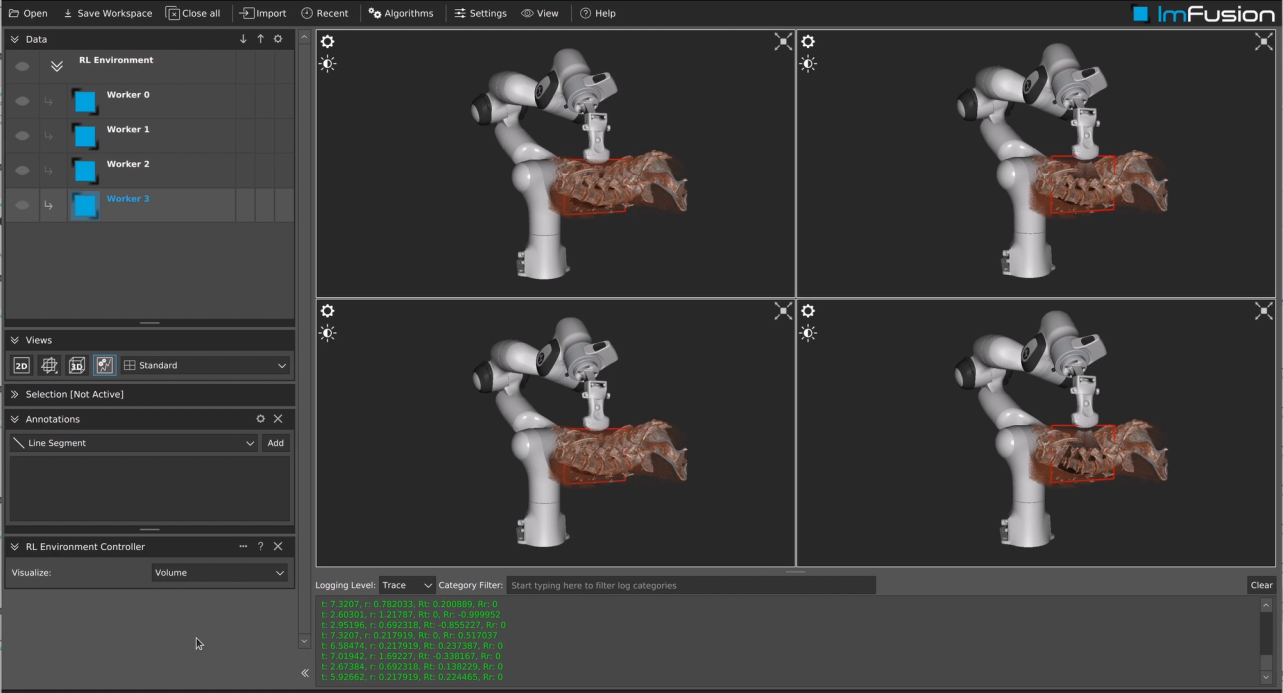
We provide building blocks for real-time medical and industrial robotic applications. Native support for sensor integration, image-based navigation, and interventional guidance helps you prototype, validate, and deploy robotic solutions faster.
Prototype, reproduce, and upgrade without starting over
A single installer gives you robot and sensor integrations, visualization and calibration tools, and methods in AI, computer vision, and medical imaging.
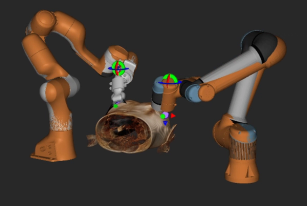
Robot and sensor integration
Uniform APIs expose the full capabilities of popular robotic arms, including native Cartesian control, while abstracting differences between devices. Bindings keep you aligned with ROS and NVIDIA Isaac.
- Uniform APIs across supported robotic arms
- Native Cartesian control strategies
- Stable bindings for ROS and NVIDIA Isaac
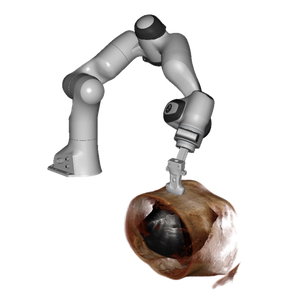
Robotic ultrasound toolbox
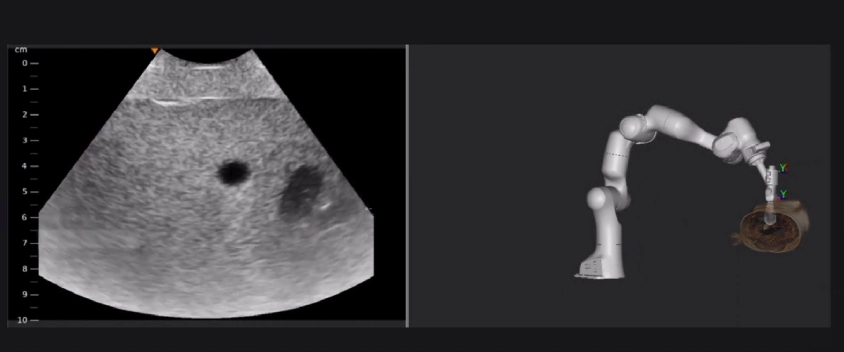
Native utilities for recording ultrasound images using the robot as a tracking device, and for planning trajectories on clinical data, including a force controller compatible with cobots so you can keep contact and probe direction in challenging scenarios.
- Record ultrasound with the robot as the tracker
- Trajectory planning on clinical data
- Cobot force controller for contact and probe direction
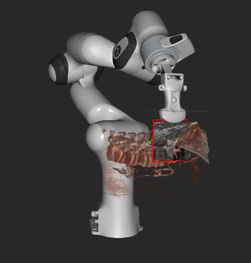
Calibration and ROS
Built-in hand-eye calibration between a robot and an RGB or RGB-D camera, an optical tracking device, or an ultrasound probe. Use ROS message serialization without installing ROS first — including on Windows — with an abstraction layer that stays compatible with ROS 1 and ROS 2.
- Hand-eye calibration (camera, tracker, ultrasound probe)
- ROS 1/2 abstraction, ROSBag read/write, ROS-O on recent Ubuntu
- MoveIt integration without forcing an immediate migration
Video tutorials
Discover the fastest path to robotic ultrasound with ImFusion Suite
ImFusion Suite Robotics Module: advanced intra-operative navigation with robotic ultrasound
Complex workflow made simple: robotic ultrasound for intra-operative navigation
Get a technical walkthrough of the platform to see our key workflows in action and assess fit.
Product Demo
In a product demo, we show you how the ImFusion Suite, SDK, and ImFusion Labels support medical imaging and data annotation workflows. We focus on the capabilities relevant to your application and discuss directly how our technology could fit into your product or support your use case.
- See integration points mapped to your specific tech stack
- Identify bottlenecks before committing development resources
- Validate data format compatibility and transformation requirements
- Get immediate answers from engineers who built the system